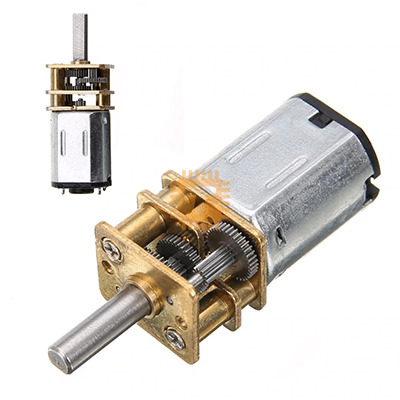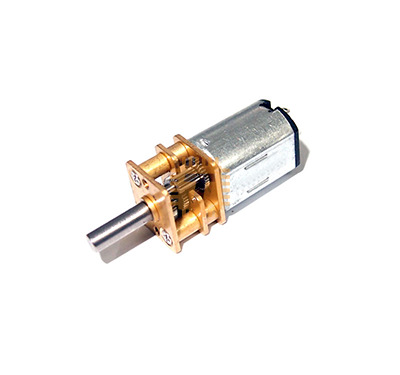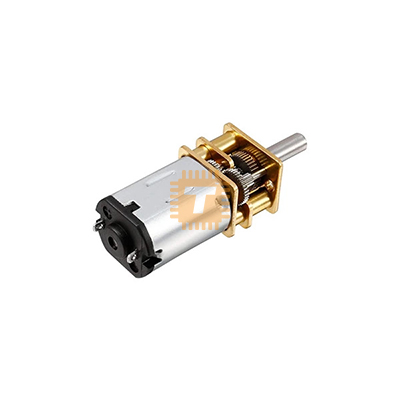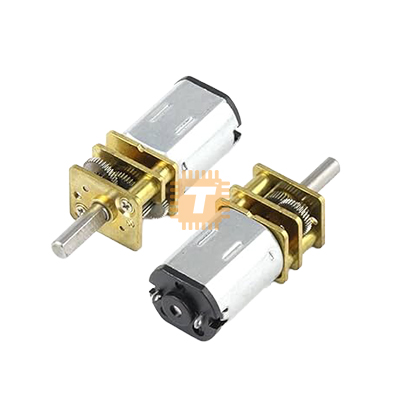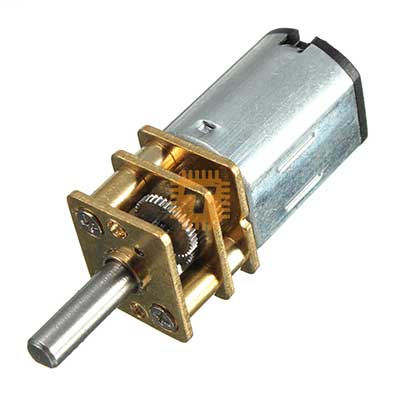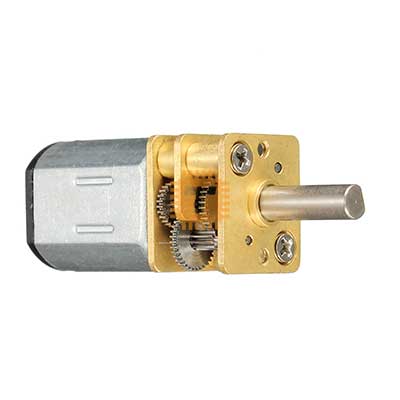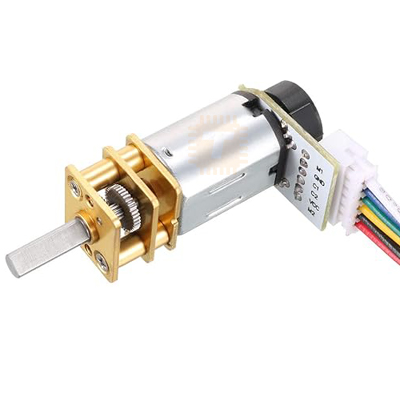
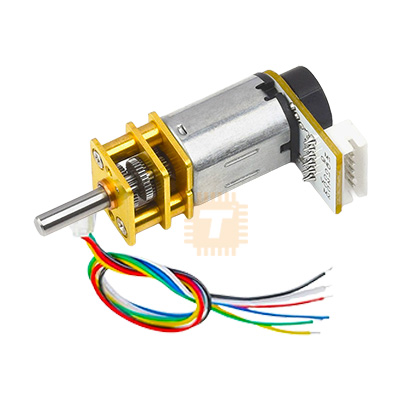
N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder
Price in Sri Lanka
DC MotorsRobotics
Tronic.lk
Rs 1,650
In stock
Updated 01 Nov 2026
Opening hours
Closed now
- Monday09:00 - 19:00
- Tuesday09:00 - 19:00
- Wednesday09:00 - 19:00
- Thursday09:00 - 19:00
- Friday09:00 - 19:00
- Saturday09:00 - 19:00
- SundayToday09:00 - 19:00
Search for it on
Description
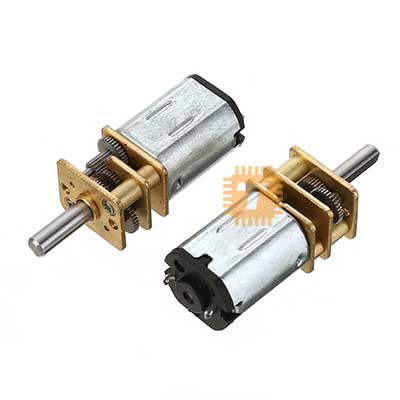
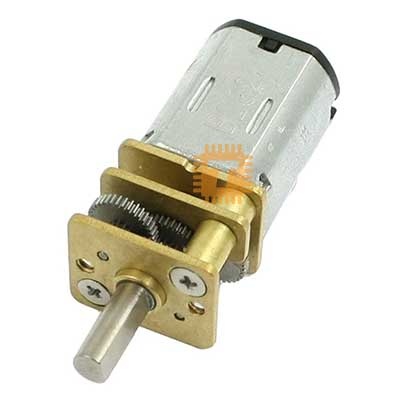
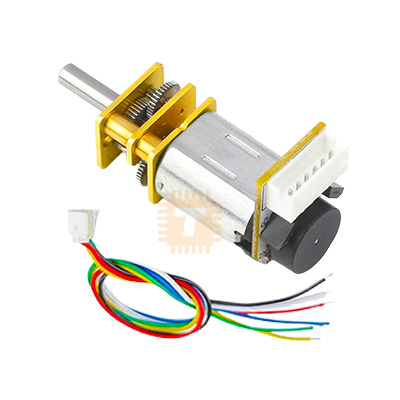
The N20 Miniature Metal Gear Motor with Dual-Channel Hall Effect Quadrature Encoder (6V / 200 RPM / 10mm D-Shaft) is an all-in-one, high-precision DC micro gear motor engineered for closed-loop speed control, accurate odometry, and angular positioning in compact robotic systems. Combining a miniature brushed DC motor core with an all-metal micro spur gearbox and a rear-mounted magnetic Hall-effect quadrature encoder PCB, it delivers high output torque and low-speed stability while providing 2-channel quadrature pulse feedback. With a standardized 3mm D-shaped output shaft extending 10mm and an ultra-compact form factor, this motor is widely utilized in micro robotics, balance bots, smart toy vehicles, 2WD/4WD mini rovers, automated locks, electronic measurement devices, and medical actuator mechanisms.
Specifications
- Motor Model / Type: GA12-N20 Micro DC Gear Motor with Magnetic Encoder
- Rated Operating Voltage: 6.0 V DC (Operating Range: 3.0V to 9.0V DC)
- No-Load Output Speed: Approx. 200 RPM (±10% at 6.0V DC)
- No-Load Current: ≤ 60 mA (Typ. 40 mA to 50 mA at 6.0V)
- Rated Load Speed: Approx. 150 to 160 RPM
- Rated Load Current: ≤ 150 mA
- Rated Load Torque: Approx. 0.3 kg·cm (0.03 N·m / 4.2 oz-in)
- Stall Torque: Approx. 1.2 kg·cm to 1.6 kg·cm (0.12 N·m to 0.16 N·m)
- Stall Current: Approx. 600 mA to 750 mA (at 6.0V DC)
- Gearbox Type: All-Metal Micro Spur Reduction Gearbox
- Gear Reduction Ratio: Approx. 1:50 to 1:100 (Nominal for ~200 RPM @ 6V)
- Encoder Specifications:
- Encoder Type: Dual-Channel Incremental Magnetic Hall Effect Quadrature Encoder
- Encoder Operating Voltage (VCC): 3.3 V to 5.0 V DC
- Signal Output Format: 2-Channel Square Wave (Channel A & Channel B with 90° Phase Offset)
- Base Pulse Count (CPR): Typically 3 to 7 Pulses Per Revolution (PPR) per channel at the raw motor shaft
- Output Resolution (PPR at Output Shaft): CPR × Gear Ratio (Provides hundreds of quadrature counts per revolution for fine odometry)
- Output Shaft Specifications:
- Shaft Type: Single Flat D-Shaft (D-Cut for secure wheel/gear hub fastening)
- Shaft Diameter: 3.0 mm (D-Cut flat thickness approx. 2.5 mm)
- Shaft Length: 10.0 mm (Usable extension from gearbox faceplate)
- Interface Connector: 6-Pin Micro JST-ZH (1.5mm pitch) or Solder-Pad Ribbon Lead
- Operating Ambient Temperature: -10°C to +60°C
- Overall Dimensions: Approx. 12 mm × 10 mm × 38 mm to 40 mm (Excluding output shaft; Total length approx. 50 mm)
- Net Weight: Approx. 14 g to 16 g
Wiring Pinout (Standard 6-Wire Interface)
- Red (M+ / Motor +): Motor Power Supply (+3V to +9V DC; PWM drive input)
- Black (M- / Motor -): Motor Power Ground / Return (Swap with Red to reverse rotation direction)
- Blue (VCC): Encoder Logic Power Supply (+3.3V or +5.0V DC)
- Green (GND): Encoder Ground (0V / Common Ground with microcontroller)
- Yellow (Phase A / OUT_A): Hall Sensor Channel A Digital Output (Square Wave)
- White (Phase B / OUT_B): Hall Sensor Channel B Digital Output (Square Wave, 90° out of phase)
Features
- Dual-Channel Quadrature Feedback: 90° phase-shifted Channel A and B outputs allow microcontroller timers/interrupts to determine both high-precision rotational speed and direction of rotation.
- Rugged All-Metal Gearbox: Heavy-duty brass and steel spur gears offer high durability, low backlash, and strong resistance to gear stripping under stall or shock loads.
- Micro-Compact Form Factor: Standard 12mm × 10mm cross-section fits into extremely tight spaces inside miniature robot chassis and handheld devices.
- D-Shaped 10mm Drive Shaft: Ensures non-slip mounting for wheels, pulleys, couplings, and robotic linkages using standard M3 set screws.
- Low Power Consumption: Highly efficient core delivers smooth torque with minimal quiescent and loaded current draw, ideal for Li-ion battery-powered setups.
Common Applications
- Miniature Robotics & Rovers: Micro 2WD/4WD wheeled mobile robots, line-tracking bots, and micromouse maze runners requiring precise wheel odometry.
- Self-Balancing Micro Bots: Real-time PID speed and angle stabilization using high-speed quadrature encoder feedback.
- Automated Locking & Access Systems: Smart deadbolts, safe locks, and electronic latch actuators.
- Pan-Tilt & Camera Gimbals: Precise low-speed positioning for miniature security cameras and optical tracking mounts.
- Laboratory & Medical Devices: Miniature peristaltic pumps, syringe drivers, and motorized fluid valves.
Usage Tips
- Motor Driver Selection: Drive the motor power lines (Red/Black) using an H-Bridge motor driver (such as the DRV8833, TB6612FNG, or L298N). Do not attempt to power the motor coils directly from microcontroller GPIO pins.
- Encoder Supply Voltage: Power the encoder logic (VCC / Blue) with 3.3V or 5V matching your microcontroller logic level. Ensure the Green (GND) wire shares a common ground with both the motor driver power supply and the microcontroller.
- Microcontroller Interfacing: Connect Phase A (Yellow) and Phase B (White) directly to Hardware Interrupt-capable GPIO pins on your microcontroller (e.g., Arduino, ESP32, STM32, or Raspberry Pi Pico) to capture quadrature pulses using internal encoder counters without missing counts.
- Direction Decoding Logic: When rotating forward, Phase A leads Phase B. When rotating in reverse, Phase B leads Phase A. Checking the state of Phase B inside the Phase A rising-edge interrupt service routine (ISR) provides instantaneous direction tracking.
- Avoid Sustained Stalling: While the all-metal gearbox is rugged, sustained mechanical stalling at full 6V power can cause thermal degradation of the brushed core or accelerate gear wear. Implement software overcurrent protection or current monitoring.
Frequently asked questions
What is the price of N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder in Sri Lanka?▾
The current price of N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder in Sri Lanka is Rs 1,650 at Tronic.lk.
Is N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder available in Sri Lanka?▾
Yes, N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder is currently in stock at Tronic.lk in Sri Lanka.
Where can I buy N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder in Sri Lanka?▾
You can buy N20 Gear Motor 6V 200RPM Shaft 10mm with Hall Sensor Encoder in Sri Lanka at Tronic.lk. Visit 37left.lk to compare prices across multiple shops and find the best deal.
Loading...